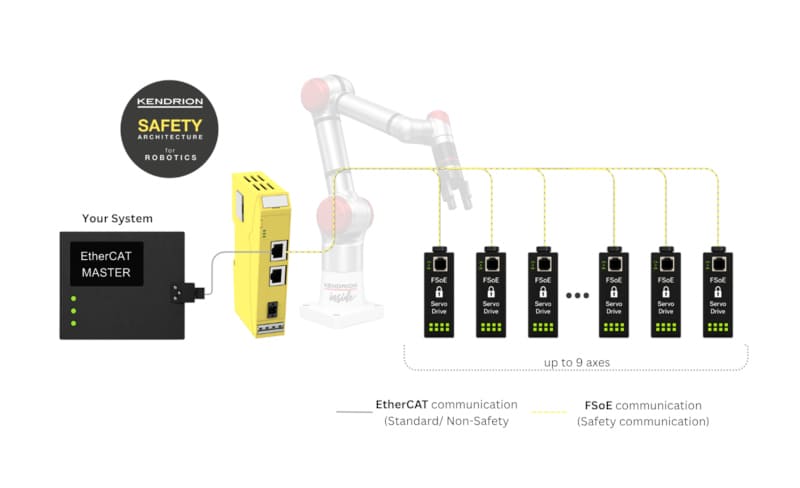
The Kendrion Safety PLC allows the EtherCAT master to communicate directly with safe FSoE servo drives. This ensures continuous, uninterrupted safety communication for robot systems with up to nine axes.
Benefits for Robot Manufacturers and System Integrators:
- No Proprietary Lock-in: Integrates smoothly into existing EtherCAT-based robotics systems and standard FSoE drives without relying on proprietary robot controllers.
- Custom Customization: Manufacturers retain the flexibility to incorporate their own functions, unique kinematics, and additional I/O systems.
- Easy Sensor Integration: Simplifies the connection of safety-relevant hardware such as laser scanners, encoders, and advanced sensors.
This open system architecture provides maximum flexibility for developing future robotics platforms while ensuring full compliance with evolving global safety requirements.
Robotic Functional Safety: Kendrion Safety Architecture for ISO 10218:2025
The updated ISO 10218:2025 standard expands the scope of robotics safety, mandating secure integration into applications and robotic cell environments. Beyond basic position and speed, modern compliance requires a stronger focus on force monitoring, dynamic safety zones, and collaborative application safety functions. [
The Kendrion Safety Architecture for Robotics addresses these challenges by combining a SIL3/PLe certified Safety PLC with a specialized robotics library for advanced kinematic safety functions.
Real-Time Kinematic Safety Monitoring for Industrial Robots and Cobots
The Kendrion Safety PLC performs real-time kinematic safety monitoring across the entire robot’s movement. It processes safety-relevant data from all connected axes and drives simultaneously.
Key capabilities of the system include:
- Comprehensive Tracking: Monitors position, speed, forces, torques, and customizable safety zones for both traditional industrial robots and cobots.
- High-Speed Processing: Processes kinematic safety functions with an ultra-low minimum cycle time of 2 ms.
- FSoE Integration: Works with Fail Safe over EtherCAT (FSoE) drives to implement critical safety functions like STO (Safe Torque Off), SS1 (Safe Stop 1), and application-specific zone monitoring.
Scalable Robotics Safety Solutions: Motion, Force, and Zone
To fit diverse industrial applications, Kendrion offers its robot safety architecture in three scalable versions:
1. Motion Version: Covers essential position and speed monitoring. It is designed specifically for traditional industrial robot configurations.
2. Force Version: Broadens safety capabilities by adding model-based and optional sensor-based force and torque monitoring. This version is ideal for safe human-robot collaboration (HRC).
3. Zone Version: Supports the monitoring of up to 20 dynamic safety zones. It allows flexible protection of work areas and enables highly efficient, modern HRC applications.
Note: This architecture accommodates serial robotic structures from two to nine axes, supporting both linear and rotary movements.
High Compatibility with Existing Robotics Platforms
The Kendrion Safety PLC allows the EtherCAT master to communicate directly with safe FSoE servo drives. This ensures continuous, uninterrupted safety communication for robot systems with up to nine axes.
Benefits for Robot Manufacturers and System Integrators:
- No Proprietary Lock-in: Integrates smoothly into existing EtherCAT-based robotics systems and standard FSoE drives without relying on proprietary robot controllers.
- Custom Customization: Manufacturers retain the flexibility to incorporate their own functions, unique kinematics, and additional I/O systems.
- Easy Sensor Integration: Simplifies the connection of safety-relevant hardware such as laser scanners, encoders, and advanced sensors.
This open system architecture provides maximum flexibility for developing future robotics platforms while ensuring full compliance with evolving global safety requirements.