This document explains how to synchronise 2 drives in torque sharing control. It provides key data and the architecture needed to achieve the outlined performance.
This application aims to explain how to control two mechanically linked motors in speed control mode. In this example, each motor is independently controlled by its own closed-loop drive. Closed-loop
control is essential for mastering both speed and torque. We will see that torque control is crucial to ensure balance between the two motors.
Some drives feature a position loop, and it may seem like a good idea to synchronize by position—like an electronic shaft, for example. However, it is usually more beneficial to choose a torque masterslave control. The advantage is ensuring that the effort provided by both motors is equal.
Synchronizing by position could create torque imbalances due to mechanical imperfections or uneven reactions on either side of the applied effort. The torque “synchronization” proposed here ensures balanced torque and forces. The master drive receives the speed command—which may or may not be ramped internally. In fact, we can imagine the master having a position loop to follow a specifi profile.
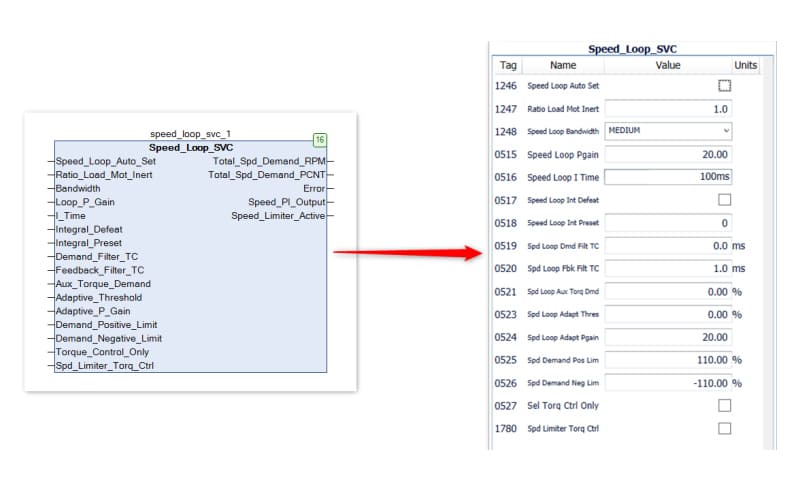
The master’s torque reference is sent to the slave drive, which will be controlled purely in torque. The speed loop must be disabled, and only the torque command applied. The key point is not the precision of the torque transmitted from master to slave but rather the speed of the exchange.