The TF5420 TwinCAT 3 Motion Pick-and-Place software package is installed together with the TF5400 software package.
TF5420 TwinCAT 3 Motion Pick-and-Place executes multi-dimensional motions. It was specially developed for the requirements of pick-and-place applications. It should be applied to motions where the precise path dynamics in segment transitions are not so important, but where the user wishes to get from one point to another as quickly as possible.
The Tc3_McCoordinatedMotion library contains all the associated function blocks.
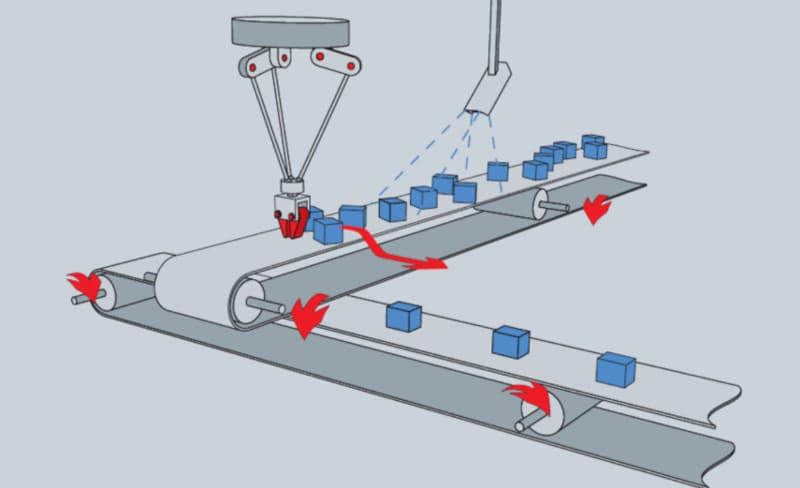
A Conveyor Tracking object can be used to synchronize an axes group with a conveyor belt. It is added as a child object to a Coordinate Frame object. While the Coordinate Frame describes the static transformation (translation and/or rotation) to the conveyor belt system, the Conveyor Tracking object handles the dynamic part of the tracking.
The dynamics parameters are default values that are used when MC_DEFAULT is chosen for the corresponding parameter in the MC_TrackConveyorBelt function block instance.